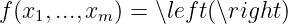1.3 Continuous mapping and function

Definition 1.3.1 A mapping f:E→Rp(E⊆Rm) is continuous at x0∈E if for any ϵ>0, there exists δϵ>0 such that for any x∈E subjecting to ∥x−x0∥<δϵ, ∥f(x)−f(x0)∥<ϵ.

Theorem 1.3.2 A mapping f:E→Rp(E⊆Rm) is continuous at x0∈E is equivalent to that for any xn∈E, limn→+∞xn=x0→limn→+∞f(xn)=f(x0).

Note When n→+∞, ∥xn−x0∥→0, ∥f(xn)−f(x0)∥→0. The continuity has nothing to do with the selection of the norm.

Theorem 1.3.3 If K⊆Rm is a bounded closed set, f is continuous on K meaning f is continuous at any x0∈K, then f(K)⊆Rp is also bounded closed. Particularly, if p=1, f has the maximum and minimum on K.

Proof For any yn∈f(K), there exists xn∈K such that yn=f(xn). Given K is bounded closed, so there exists a convergent subsequence {xnk} of {xn} such that limk→+∞xnk=x0∈K. f is continuous at x0∈K, so limk→+∞ynk=limk→+∞f(xnk)=f(x0)∈f(K). So f(K) is bounded closed.

When p=1, f(K)⊆R is bounded closed. Let β=supf(K) and α=inff(K). α,β cound be approached by sequences in the set f(K). Since f(K) is closed, so α,β∈f(K), so β=maxf(K) and α=minf(K). ◻

Definition 1.3.4 A set E⊆Rm is a path-connected set if for any a,b∈E, there exists a continuous mapping x:[0,1]→Rm such that x(0)=a,x(0)=b and for any t∈[0,1], x(t)∈E.

Theorem 1.3.5 If E⊆Rm is a path-connected set, f is continuous on E, then f(E)⊆Rp is also path-connected. Particularly, if p=1, f(E) is a interval with intermediate value theorem.

Example 1.3.1 Continuous mappings and functions.

  • Constant mapping.
  • Linear mapping L:Rm→Rp. For any x,y∈Rm, ∥L(x)−L(y)∥=∥L(x−y)∥=∥L(∑i=1m(xi−yi)ei)∥≤∑i=1m|xi−yi|∥L(ei)∥≤∥x−y∥∞∑i=1m∥L(ei)∥

    So L is a Lipschitz function, is uniformly continuous.

  • Norm ∥⋅∥:x↦∥x∥. |∥x∥−∥y∥|≤∥x−y∥, Lipschitz.
  • The addition Rm×Rm→Rm,(x,y)↦x+y, number multiplication R×Rm→Rm,(λ,x)↦λx and inner product Rm×Rm→R,(x,y)↦⟨x,y⟩ between vectors.
  • f:E→R,g:E→R are continuous, then f⋅g:E→R where x↦f(x)g(x) is also continuous.
  • f:E→R is continuous and f(x0)≠0, then g:E→R where x↦1f(x) is also continuous.

Theorem 1.3.6 Assuming f:E→Rp is continuous at x0∈E and g:E→Rq is continuous at f(x0)=y0∈F, then g∘f:(E∩f−1(F))→Rq is continuous.

Theorem 1.3.7 Given f:E→Rp, E⊆Rm,

f(x1,...,xm ) = ∖left(∖right)

then f is continuous at x0∈E⇔ for any k, fk:E→R is continuous at x0.

Proof Hint. |fk(x)−fk(x0)|≤∥fk(x)−fk(x0)∥∞≤∑i=1p|fi(x)−fi(x0)|

◻

Example 1.3.2 If arbitrarily fixing one or more variable(s) will get a continuous function, does it mean the original function is continuous? No! See the example below.

Example 1.3.3 Is f(x,y)={xyx2+y2(x,y)≠(0,0)A(x,y)=(0,0) continuous?

Fix y≠0, f(x,y)=fy(x)=xyx2+y2 is continuous with respect to x. Fix y=0, f(x,0)={0x≠0Ax=0, it’s continuous when A=0. Similar when fixing x. So when A=0, fixing any variable will get a continuous function.

Now consider the continuity of binary f(x,y). When (x0,y0)≠(0,0), since x02+y02>0, according to the composition rule f(x,y) is continuous.

Now consider (x,y)=(0,0). Select a continuous curve (x(t),y(t)) with respect to t and limt=0(x(t),y(t))=(0,0), if limt=0f(x(t),y(t))≠A or even doesn’t exist, then f is not continuous at (x,y)=(0,0). Given f(t,αt)=α1+α2; when α=0, f(t,0)=0; when α=1, f(t,t)=12. f(tcos⁡1t,tsin⁡1t)=12sin⁡2t oscillates. So f is not continuous whatever A is.

Another example is f(x,y)={x2yx4+y2(x,y)≠(0,0)0(x,y)=(0,0). Even though f(t,αt)=αtα2+t2→0 for any α when t≠0, we can select other strange curves x(t),y(t) going to (0,0) yet limf(x(t),y(t)) doesn’t exist.

Example 1.3.4 Application. Assuming a linear mapping A:Rn→Rn is symmetric, meaning for any x,y, ⟨Ax,y⟩=⟨x,Ay⟩, prove that there exists a series of identity orthogonal bases v1,...,vn∈Rn and a series of eigenvalues λ1,...,λn such that Avk=λkvk.

Proof Let K={v∈Rn|∥v∥=1}. K is bounded (∥v∥=1) and closed (the norm function is continuous). f(v)=⟨Av,v⟩ is continuous with respect to v, so f has maximum point v1 on K. Arbitrarily select an identity vector w⊥v1, let u(θ)=cos⁡θv1+sin⁡θw∈K and ∥u∥=⟨u,u⟩=1. So f(u(θ))=⟨A(cos⁡θv1+sin⁡θw),cos⁡θv1+sin⁡θw⟩=cos2⁡θ⟨Av1,v1⟩+sin2⁡θ⟨Aw,w⟩+cos⁡θsin⁡θ(⟨Av1,w⟩+⟨Aw,v1⟩)=(1+o(θ))⟨Av1,v1⟩+o(θ)⟨Aw,w⟩+(θ+o(θ))(⟨Av1,w⟩+⟨Aw,v1⟩)=g(θ)

g(θ) is derivable and takes the maximum when θ=0, so g′(0)=0→⟨Av1,w⟩=0, so Av1 is perpendicular to all vectors which is perpendicular to v1, meaning that Av1⊥{v1}⊥, so there exists λ1 such that Av1=λ1v1.

It is to be proved that V1={v1}⊥={w|w⊥v1} is invariant under A. For any w∈V1, ⟨Aw,v1⟩=⟨w,Av1⟩=⟨w,λ1v1⟩=0, So AV1⊆V1.

Then the spectral decomposition is proved by mathematical induction. ◻