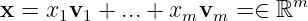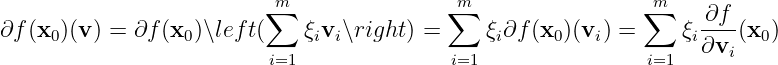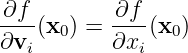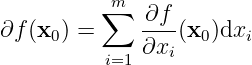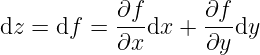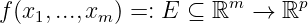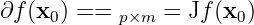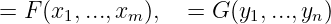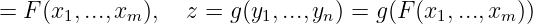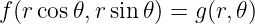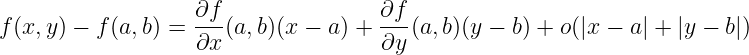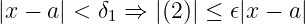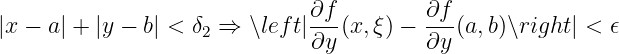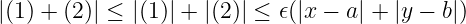2.2 Partial derivative

Given f:E→Rp, x0∈E⊆Rm is the interior point, {v1,...,vm} compose a set of bases in Rm. Therefore

x =  x1v1 + ...+ xmvm   =∈  ℝm

is called the coordinate based on v1,...,vm.

Let v=∑i=1mξivi, assuming f is differentiable at x0, then

                         ∑m               ∑m                 ∑m
∂f(x0)(v ) = ∂f (x0)∖left(   ξivi∖right ) =    ξi∂f(x0 )(vi) =     ξi ∂f-(x0)
                         i=1               i=1                i=1   ∂vi

Mark

∂f         ∂f
---(x0 ) = ---(x0)
∂vi        ∂xi

which is called the partial derivative of f at x0 over the ith component under the coordinate system (x1,...,xm). Define the coordinate-projection function xi:Rm→R,

x =↦→  xi

It’s a linear function, therefore, dxi=xi:Rm→R, xi:Rm→R,

v = ↦→ ξi

is also linear. When p=1, we have

          m∑   ∂f
∂f(x0 ) =    ----(x0)dxi
          i=1 ∂xi

which is called the (total) differential of f at x0. Here dxi are functions, not numbers! Take z=f(x,y) as an example, we have

            ∂f      ∂f
dz  = df =  ---dx + ---dy
            ∂x      ∂y

Consider ∂f(x0)(v)=∑i=1m∂f∂xi(x0)ξi=(∂f∂x1(x0)⋯∂f∂xm(x0))⏟The representative matrix of ∂f(x0)(ξ1⋮ξm)df(x0)=(∂f∂x1(x0)⋯∂f∂xm(x0))

When p>1, consider a mapping

f(x1,...,xm ) =: E ⊆ ℝm  →  ℝp

Here

∂f(x0) ==  p×m =  Jf(x0)

is called the Jacobi matrix of f at x0.

Chain rule. ∂(G∘F)(x0)=∂G(y0)∘∂F(x0)⇕J(G∘F)(x0)=JG(y0)JF(x0)

Assuming

= F (x1,...,xm ),  = G (y1,...,yn)

then (∂zi∂xj)l×m=(∂zi∂yk)l×n(∂yk∂xj)n×m∂zi∂xj=∑k=1n∂zi∂yk⋅∂yk∂xj∀i,j

If G=g is a function, i.e.

=  F(x1,...,xm ),  z = g (y1,...,yn) = g(F (x1,...,xm ))

therefore dz=∑i=1m∂(g∘F)∂xidxi=∑i=1m(∑k=1n∂z∂yk∂yk∂xi)dxi=∑k=1n[∂z∂yk∑i=1m∂yk∂xidxi]=∑k=1n∂z∂ykdykdz=∑i=1m∂z∂xidxi=∑k=1n∂z∂ykdyk

which is called the formal invariance of first-order derivative, meaning for any set of variables to express z, the form of the differential of z remains invariant.

Example 2.2.1 Orthogonal coordinate and polar coordinate. Given z=f(x,y),

f(rcos 𝜃,rsin𝜃) = g(r,𝜃)

Find the relation between ∂f∂x,∂f∂y and ∂g∂r,∂g∂θ. Notice that dz=∂z∂xdx+∂z∂ydy=∂f∂xdx+∂f∂ydydz=∂z∂rdr+∂z∂θdθ=∂g∂rdr+∂g∂θdθdx=∂x∂rdr+∂x∂θdθ=cos⁡θdr−rsin⁡θdθdy=∂y∂rdr+∂y∂θdθ=sin⁡θdr+rcos⁡θdθ∂g∂r=∂f∂xcos⁡θ+∂f∂ysin⁡θ1r∂g∂θ=∂f∂xsin⁡θ−∂f∂ycos⁡θ(∂z∂r∂z∂θ)=(∂z∂x∂z∂y)(∂x∂r∂x∂θ∂y∂r∂y∂θ)

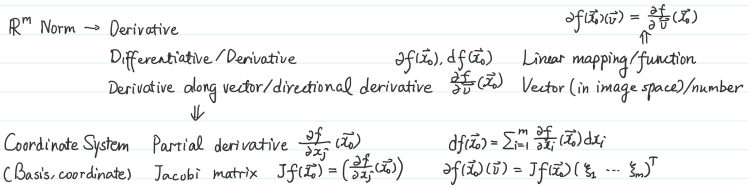
PIC

Figure 2.3: Concept Map

Theorem 2.2.1 Assuming ∂f∂x1,...,∂f∂xm is continuous on U, then f is differentiable at every point in U, and ∂f(x0)(v)=∑i=1m∂f∂xi(x0)ξi,∀x0∈U∂f(x0)=∑i=1m∂f∂xi(x0)dxi

Proof Prove only m=2. z=f(x,y), we need

  • ∂f∂x(a,b) exists.
  • ∂f∂y(x,y) exists on U near (a,b) and is continuous at (a,b).

We use the 1-norm here, so it is needed to be proven that when (x,y)→(a,b),

                   ∂f-              ∂f-
f(x,y ) − f (a,b) = ∂x (a,b)(x − a ) + ∂y(a,b)(y − b) + o(|x − a| + |y − b|)

 f(x,y)−f(a,b)−∂f∂x(a,b)(x−a)−∂f∂y(a,b)(y−b)=f(x,y)−f(x,b)−∂f∂y(a,b)(y−b)(1)+f(x,b)−f(a,b)−∂f∂x(a,b)(x−a)(2)

Since ∂f∂x(a,b) exists, for any ϵ>0, there exists δ1(ϵ,a,b)>0 such that

|x − a| < δ1 ⇒ |(2)| ≤ 𝜖|x − a|

According to Lagrange’s intermediate theorem, f(x,y)−f(x,b)=∂f∂y(x,ξ)(y−b)ξ=(1−t(x,y))b+t(x,y)y0≤t(x,y)≤1(1)=[∂f∂y(x,ξ)−∂f∂y(a,b)](y−b)

Since ∂f∂y is continuous at (a,b), for any ϵ>0, there exists δ2(ϵ)>0 such that

                              ∂f-        ∂f-
|x − a| + |y − b| < δ2 ⇒ ∖left|∂y (x,ξ) − ∂y (a,b)∖right| < 𝜖

Here |x−a|+|ξ−b|≤|x−a|+|y−b|<δ2, so |(1)|≤ϵ|y−b|. Select δ=min{δ1(ϵ),δ2(ϵ)}, then for any |x−a|+|y−b|<δ(ϵ),

|(1) + (2)| ≤ |(1)| + |(2)| ≤ 𝜖(|x − a| + |y − b|)

Terminally f is differentiable at (x,y). ◻